
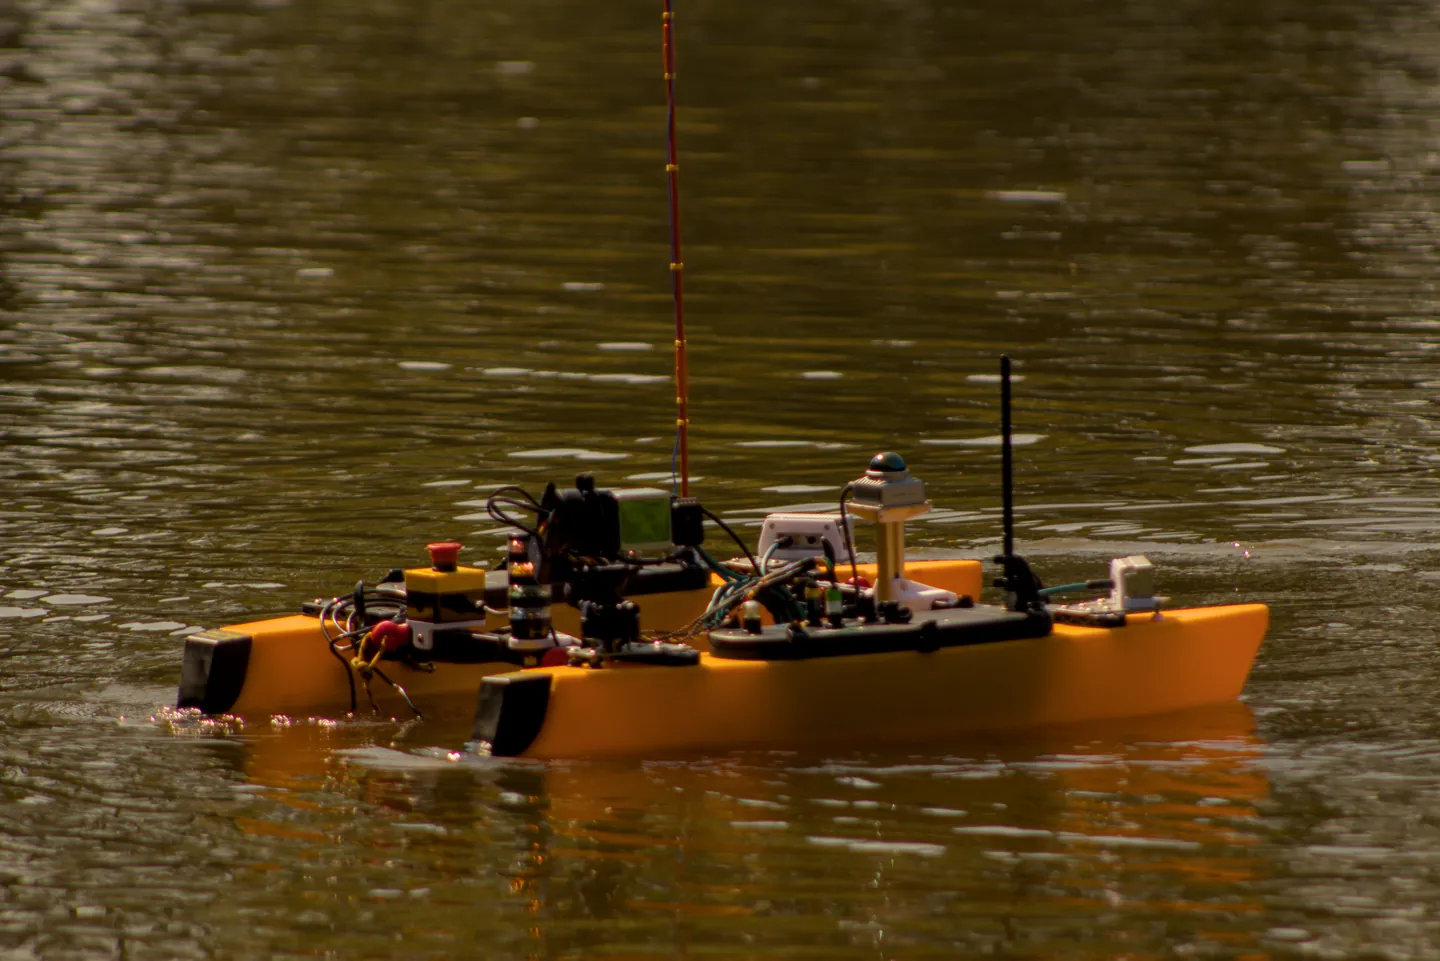
RobotX 2026
Development timeline
How we built our RobotX 2026 entry, a BlueBoat-derived surface vehicle and a modified X650 drone, from first lake tests to competition.
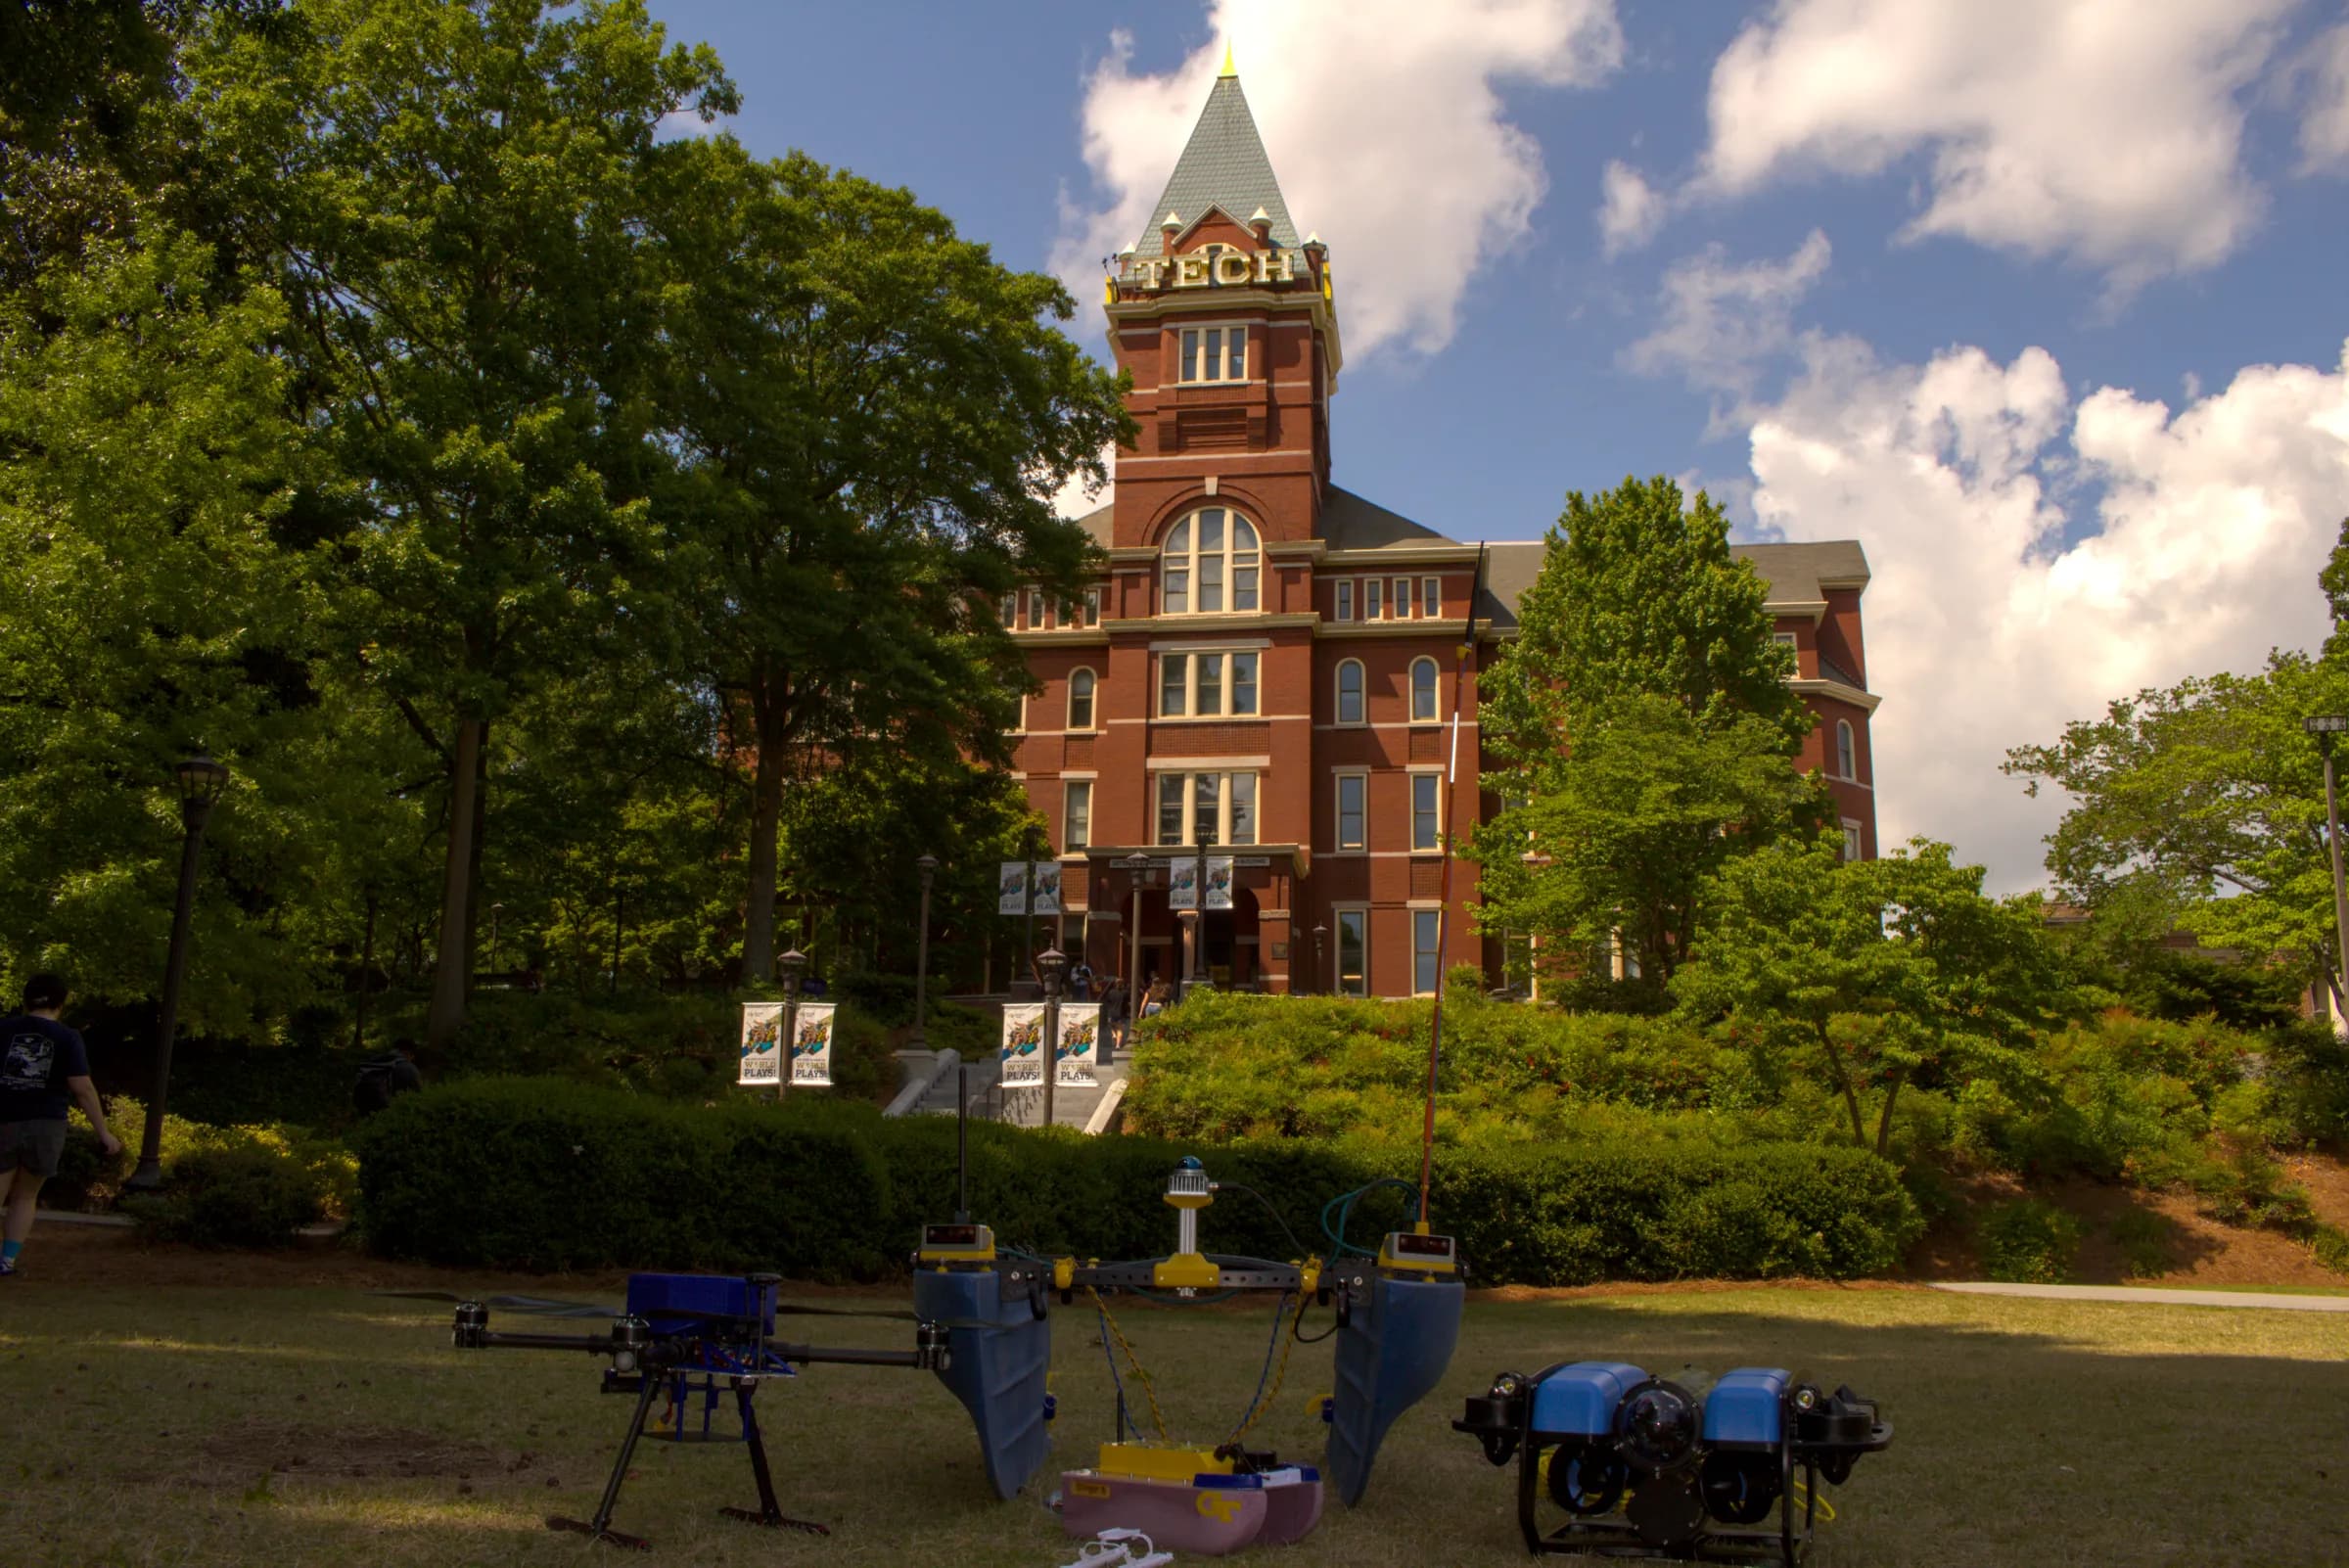
Phase one
Groundwork
Mar – Apr 2026
Coming off RoboBoat, we broke the RobotX system into subsystems, each with its own owner, and started building a second boat while the drone made its first flights.
Our first lake tests taught us to integrate on land before we get to the water, and every field day since has started with a full dry test.
Phase two
Finding our footing
May – Jul 2026
Regular lake testing turned the boat into a platform we could trust, as navigation and autonomy behaviors were tuned until they held up outside simulation.
Phase three
Taking to the air
Jul – Aug 2026
The drone joined the boat for its first joint tests, then worked through its prequalification flights and a pool test to prove it floats.
Phase four
All hands
Sep 2026 onward
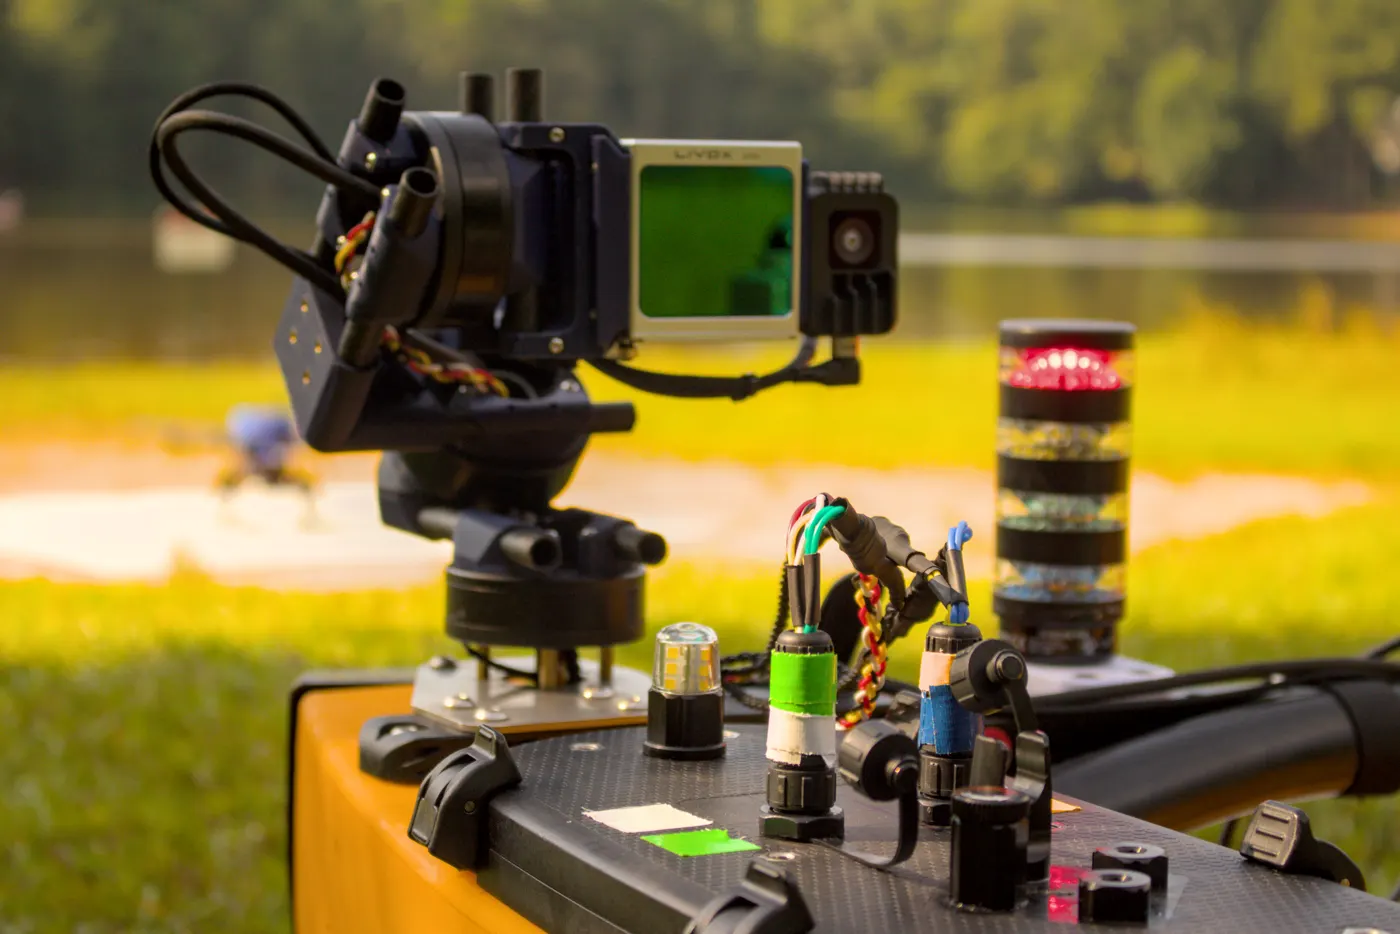
With the entry set as one boat and one drone, and every proof of readiness complete, our new sensor gimbal went on the water.
The focus now is integrating, tuning, and testing both vehicles ahead of competition.
Gallery
Test records
Objectives, time in the field, and results for each test day. Results are added as logs are reviewed.
The team tests as much as possible before the field test even begins, starting with simulations, subsystem-level verification, and a full dry test the night before a field test.
- Simulation & bench tests
- Onboard dry test
- Field test
- Post-test review
Field flight test
UAV · Selected test footage
- Objectives
- Validate autonomous waypoint following, geofence boundary enforcement, and Ainstein US-D1 radar altimeter altitude holding over open fields.
- Field time
- 45 minutes flight time across multiple battery sorties
- Results
- Confirmed stable altitude hold, verified parallel battery hot-swap procedure without avionics reboot, and demonstrated geofence failsafe containment.
Buoyancy test
UAV · Selected test footage
- Objectives
- Confirm positive buoyancy and evaluate component waterproofing integrity during controlled water immersion.
- Field time
- 1.5 hours in-pool evaluation
- Results
- Chassis demonstrated stable positive waterplane buoyancy with zero water ingress into sealed avionics and battery enclosures.
Abridged Sprint & Meeting Notes
Abridged highlights from team sprint meetings, lake test debriefs, and system integration milestones. Full archives and detailed minutes are maintained in the GT MRG Notion Wiki.
- 2026-09-25
Singapore Roster Announcement & Final Lake Test Prep
- Officially confirmed the 9-member travel roster for the 2026 Maritime RobotX Challenge in Singapore.
- Finalized GB Stables lake test objectives: dual-vehicle data collection, UTM coordinate frame integration, and USV autonomy bringup for Task 1.
- Coordinated countdown for competition deliverables due Sept 28: Technical Design Report, team video, demographics, and air/sea vehicle freight packaging.
- Technical progress: MAVROS locked at v2.14.0, gimbal transform tree verified, and light tower fabrication completed.
- 2026-09-18
Sept 12 Lake Test Debrief & Testing Policy
- Debriefed Sept 12 lake test: successfully validated active sensor gimbal stabilization on water and gathered UAV aerial perception datasets.
- Instituted mandatory bench dry-testing protocol on the night prior to every lake test to protect operational time on the water.
- Progress updates: UAV mapping autonomy testing in progress, underwater servo pressure validation complete, and Robobuoy flashing light electronics tested.
- 2026-09-11
Vehicle Prioritization & GB Stables Logistics
- Reaffirmed primary competition vehicle pair: Orangeboat (USV) and Holybro X650 Quadcopter (UAV); BlueROV development placed on hold to consolidate team resources.
- Finalized GB Stables operational call times, rain contingency procedures, and dock access logistics.
- 2026-09-04
Proof of Readiness Completion & Task Allocation
- Successfully submitted official USV, UAV, and Communications Proof of Readiness milestone packages.
- Software bringup: UTM/MGRS coordinate frame TF publisher integrated into ROS 2 launch files; light buoy classification dataset collected.
- Mechanical sign-offs: PRESto emergency stop mounting plates, custom hull cable fairings, and water shooter servo/pump bracket fabrication.
- Summer 2026
Core Systems & Multi-Vehicle Bringup
- Diagnosed and resolved BlueBoat ArduPilot motor reversing and turning issues through cross-parameter validation across hulls.
- Integrated Ainstein US-D1 radar altimeter on UAV airframe to overcome over-water optical altimetry scattering.
- Verified multi-vehicle TF coordinate transforms and brought up ground station (gt-ocs) telemetry and semantic map sharing.