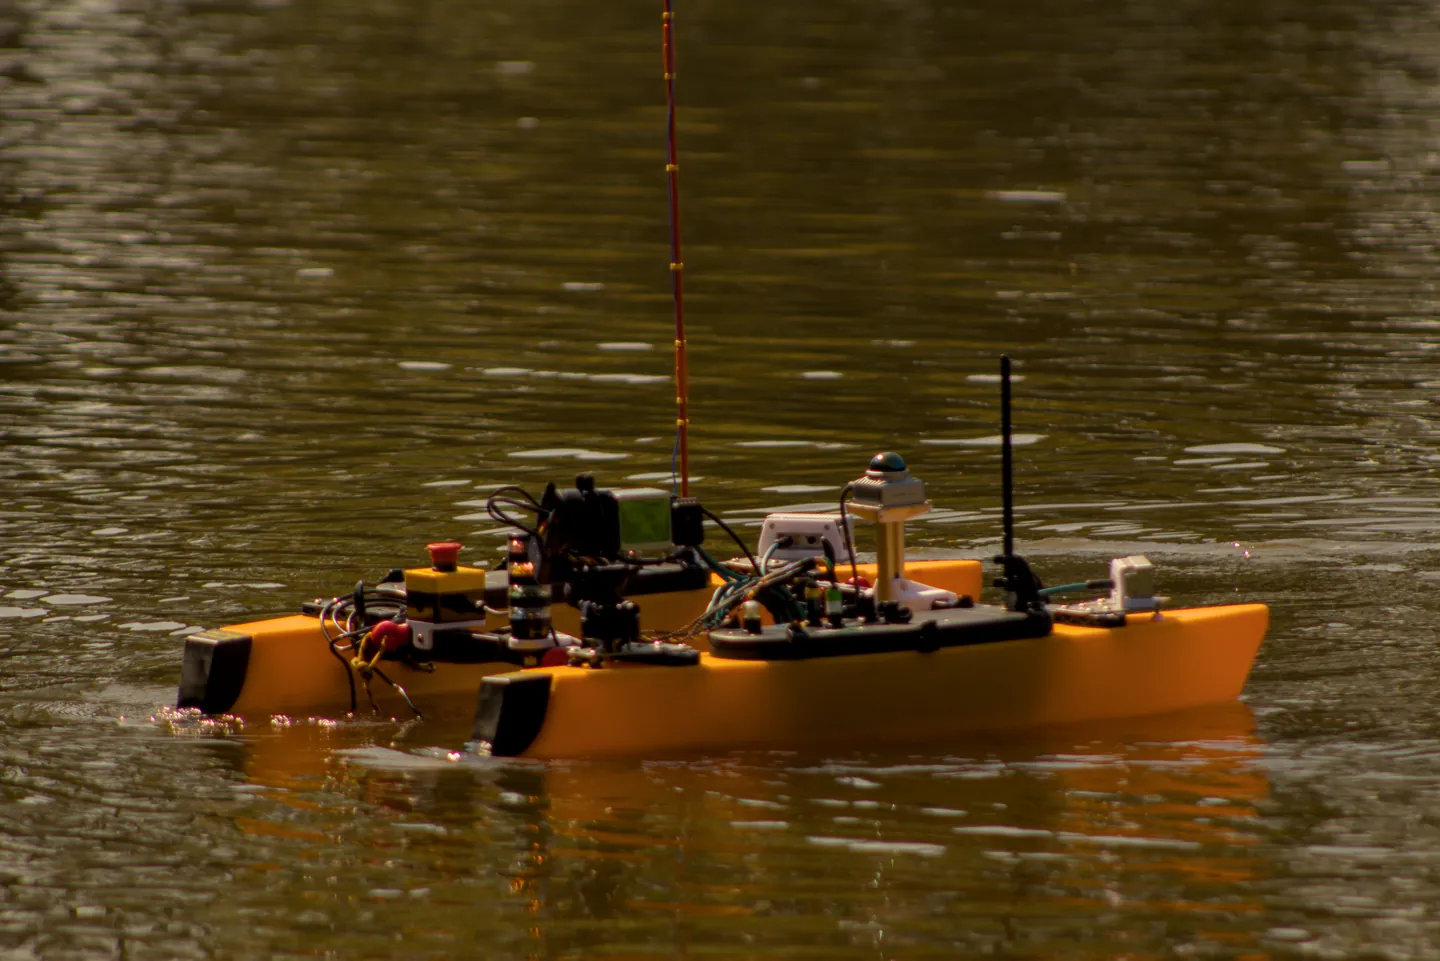
Surface vehicle
A BlueBoat-derived catamaran whose sensors turn independently of the hull: a Livox Avia LiDAR and an OAK-1 camera on a custom three-axis gimbal.
Explore the boat
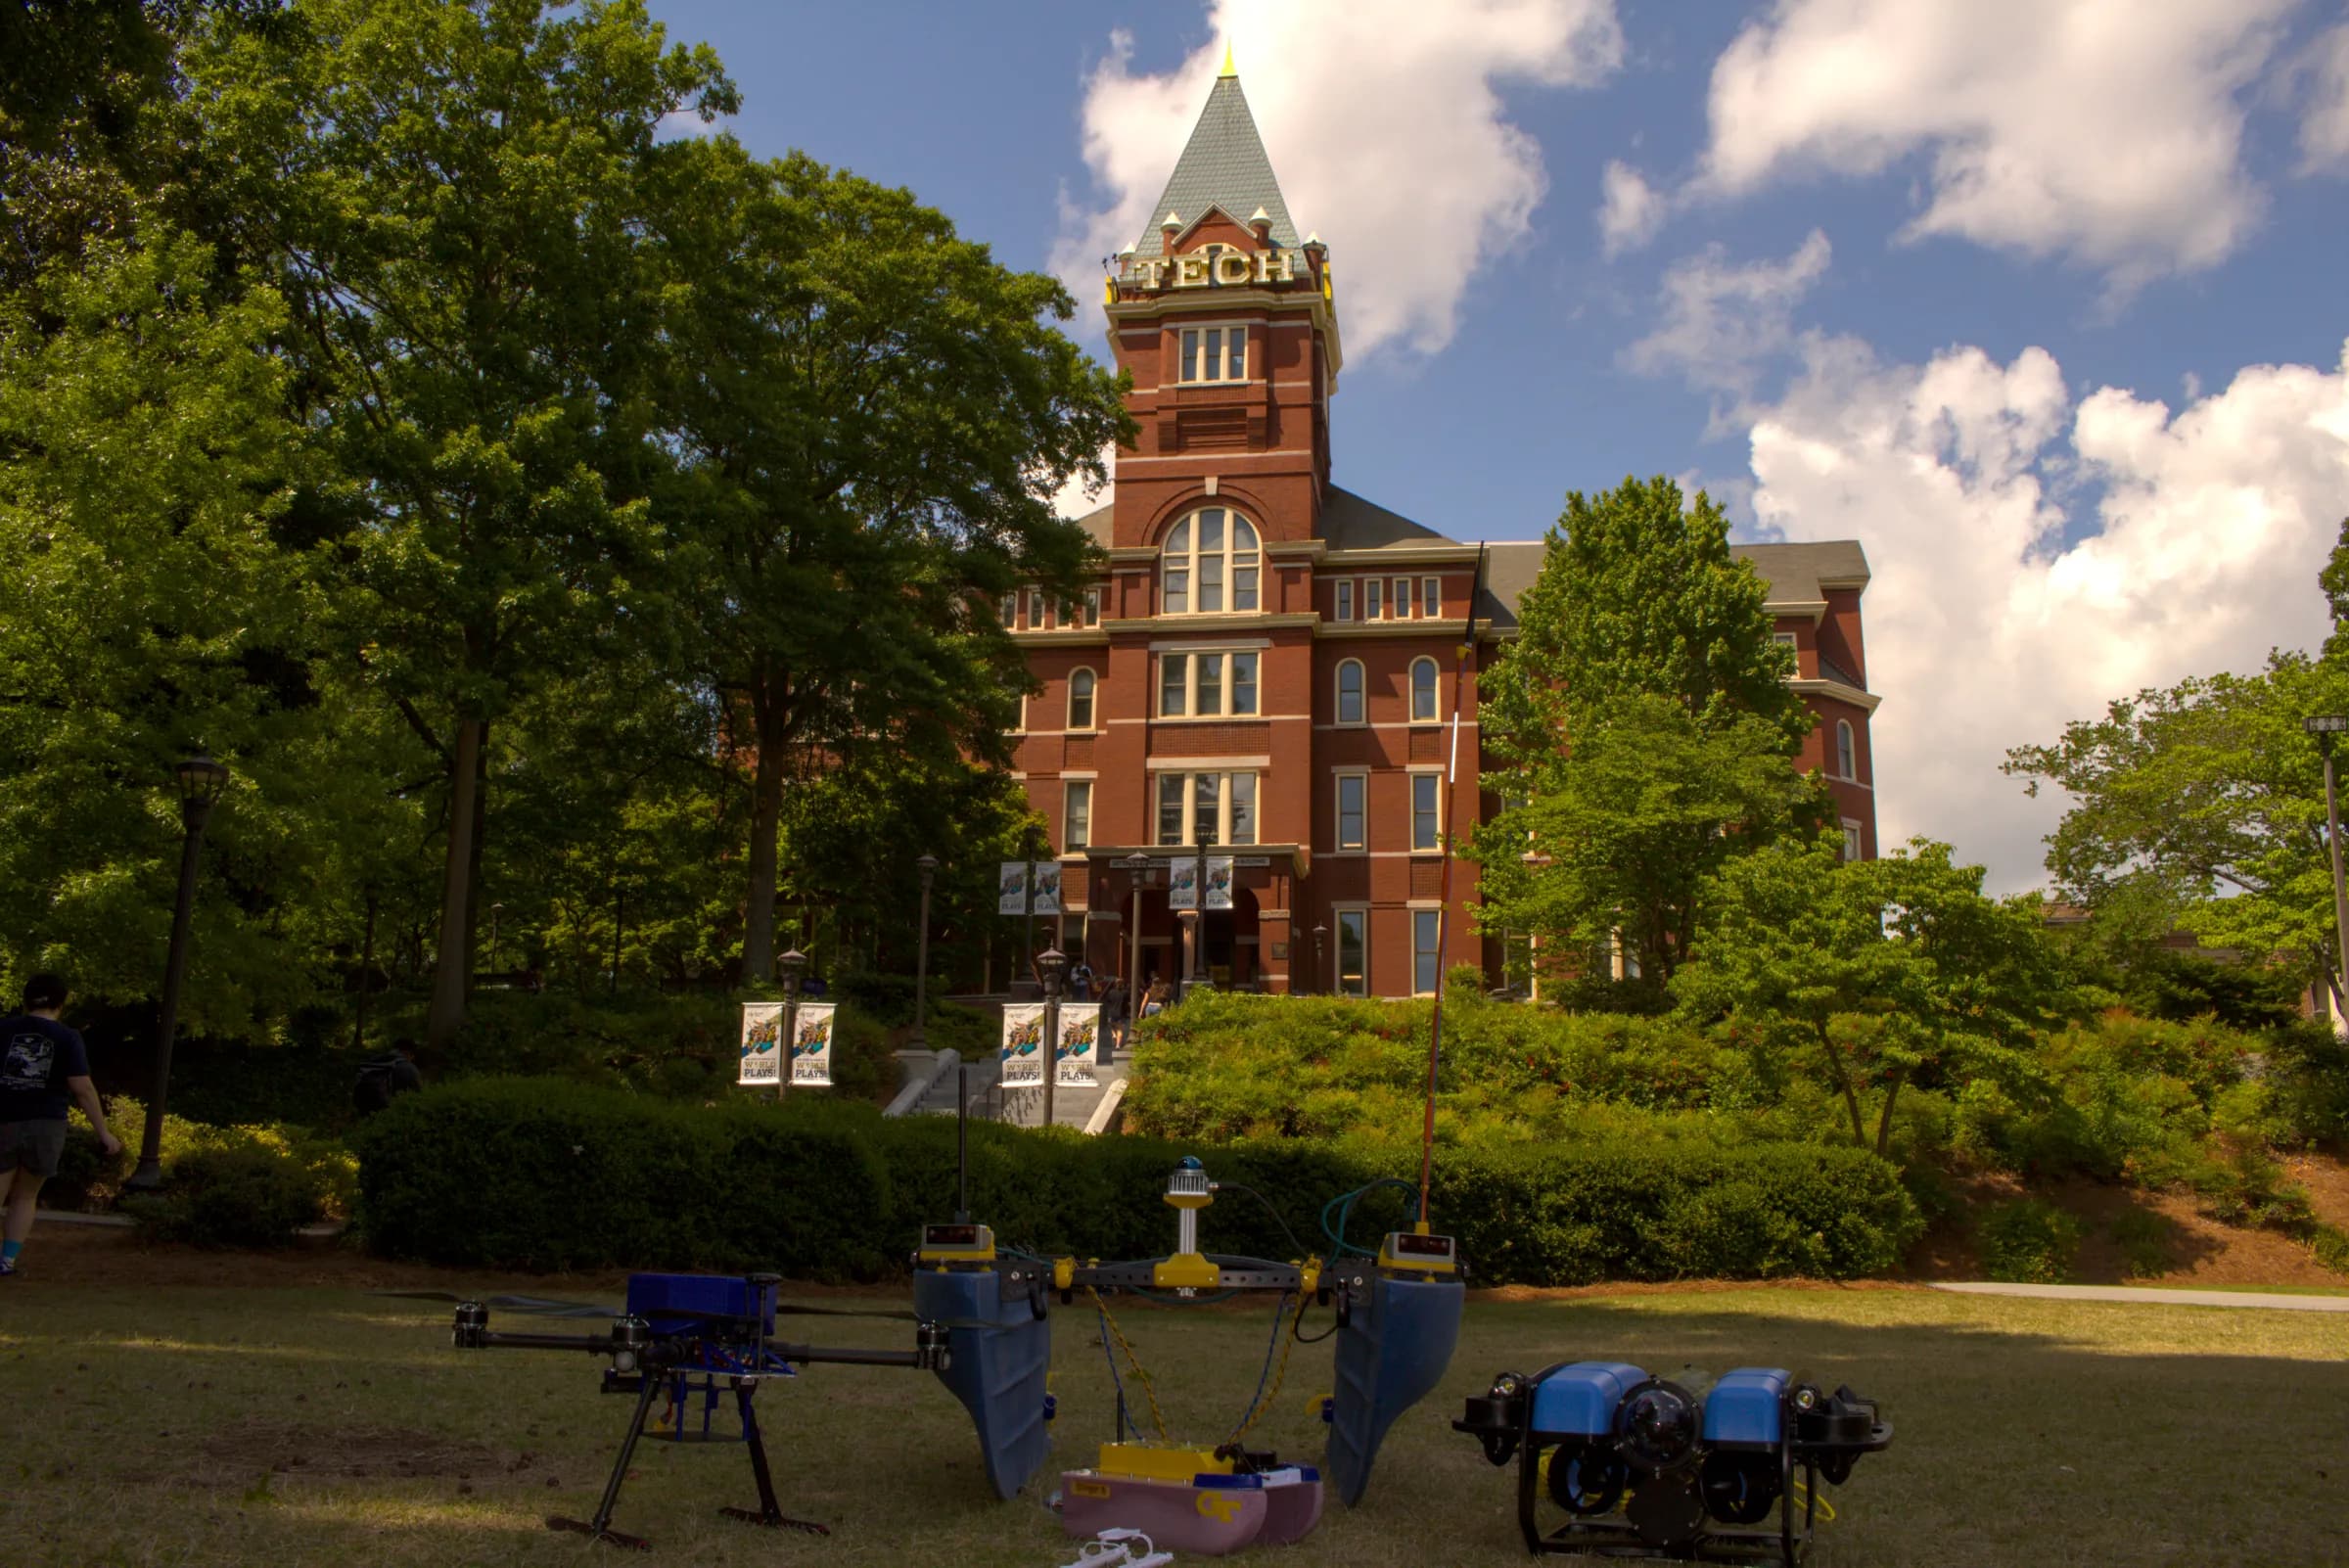
Georgia Tech Marine Robotics Group
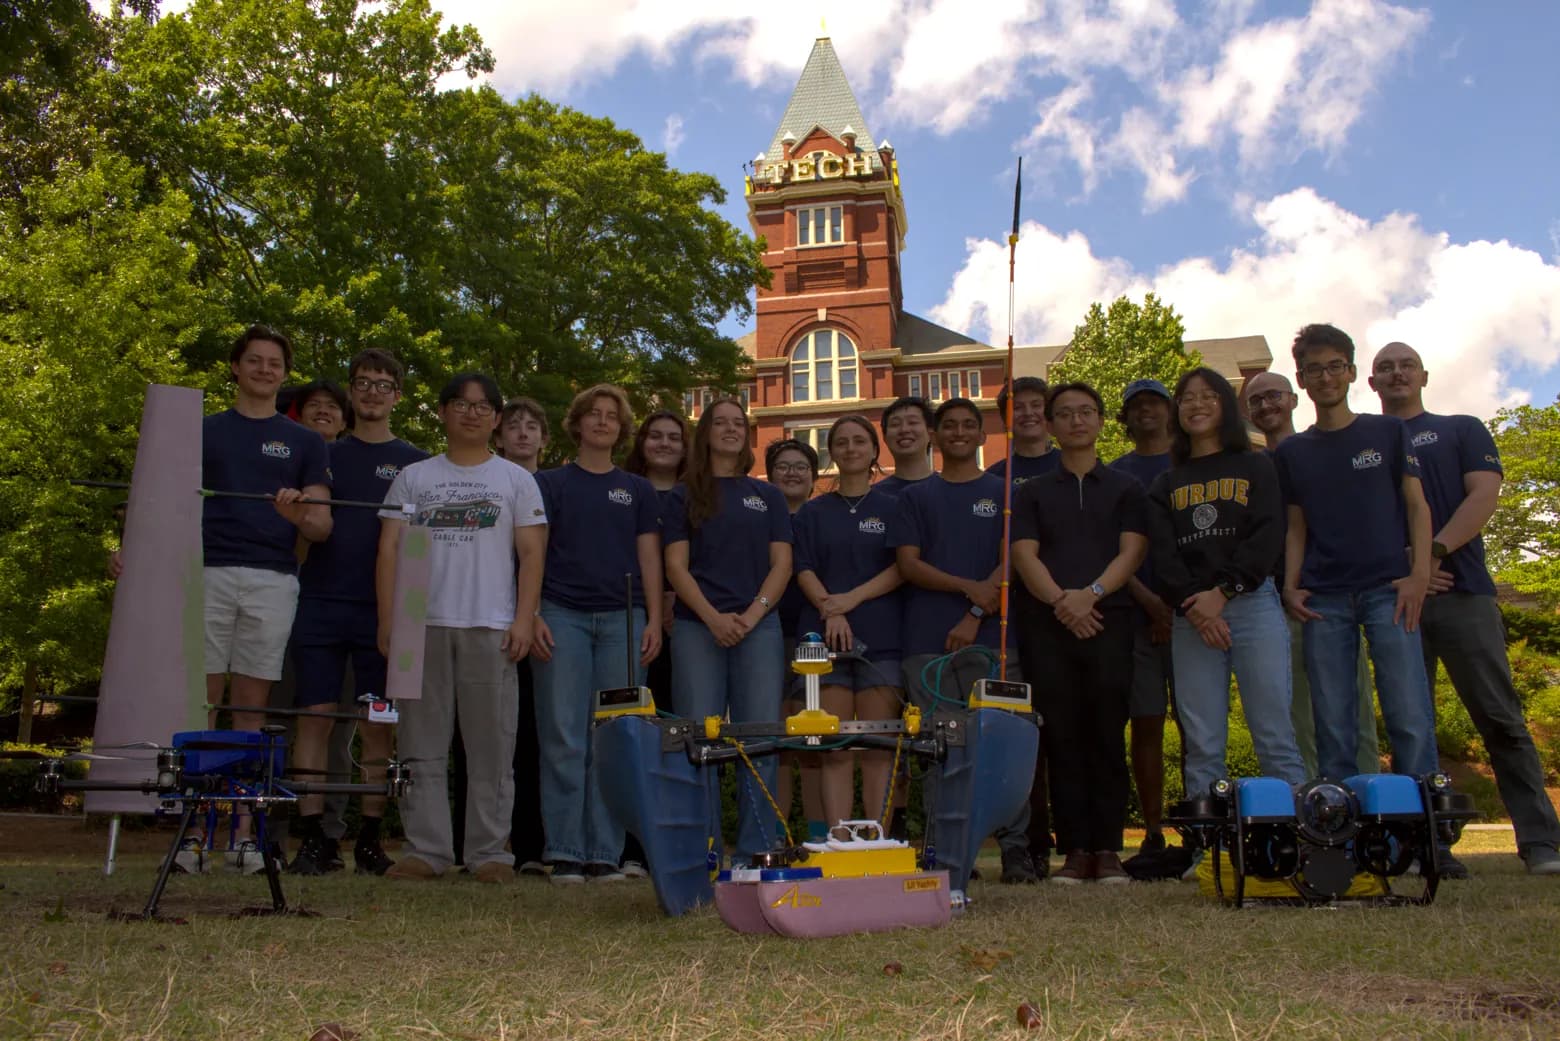
An autonomous boat and drone for the 2026 Maritime RobotX Challenge.An autonomous boat and drone for the 2026 Maritime RobotX Challenge. The boat's gimbal aims its LiDAR and camera wherever the mission needs them, whichever way the hull is pointing.
A BlueBoat-derived catamaran whose sensors turn independently of the hull: a Livox Avia LiDAR and an OAK-1 camera on a custom three-axis gimbal.
Explore the boat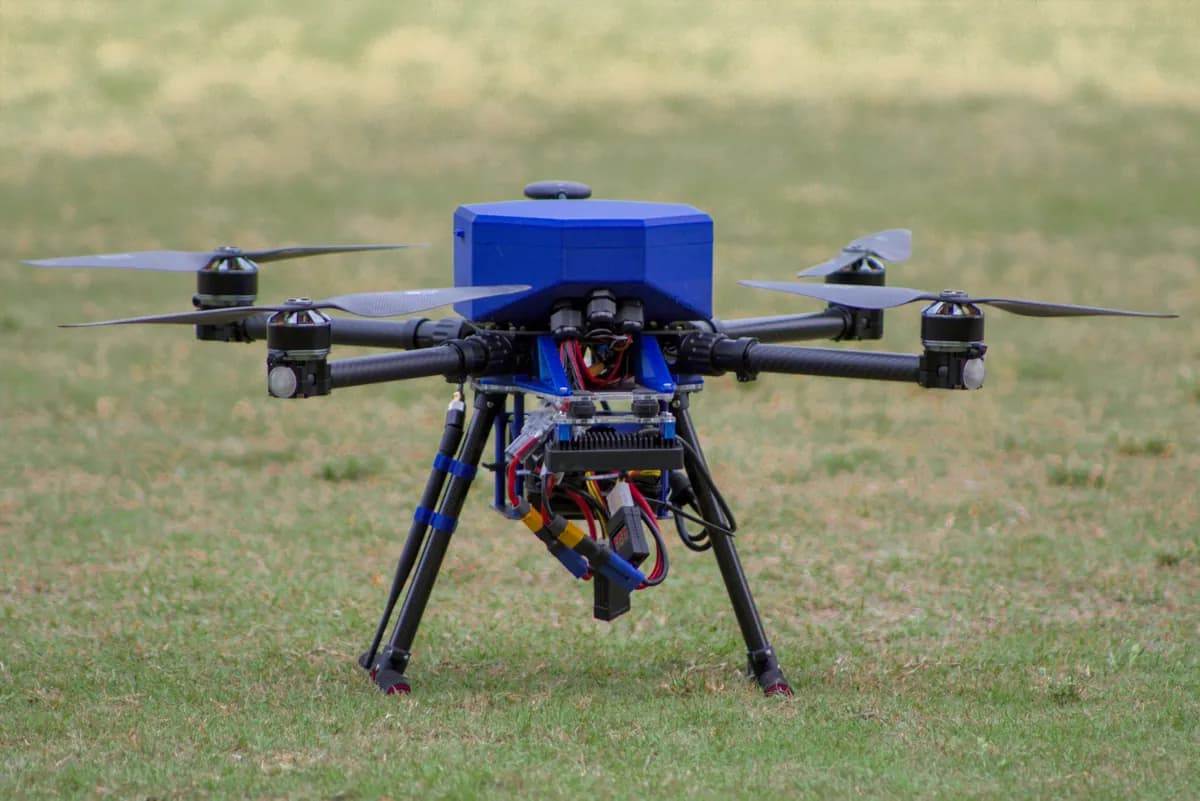
A modified Holybro X650 that scouts the course from above and releases payloads where the boat can't reach.
Explore the drone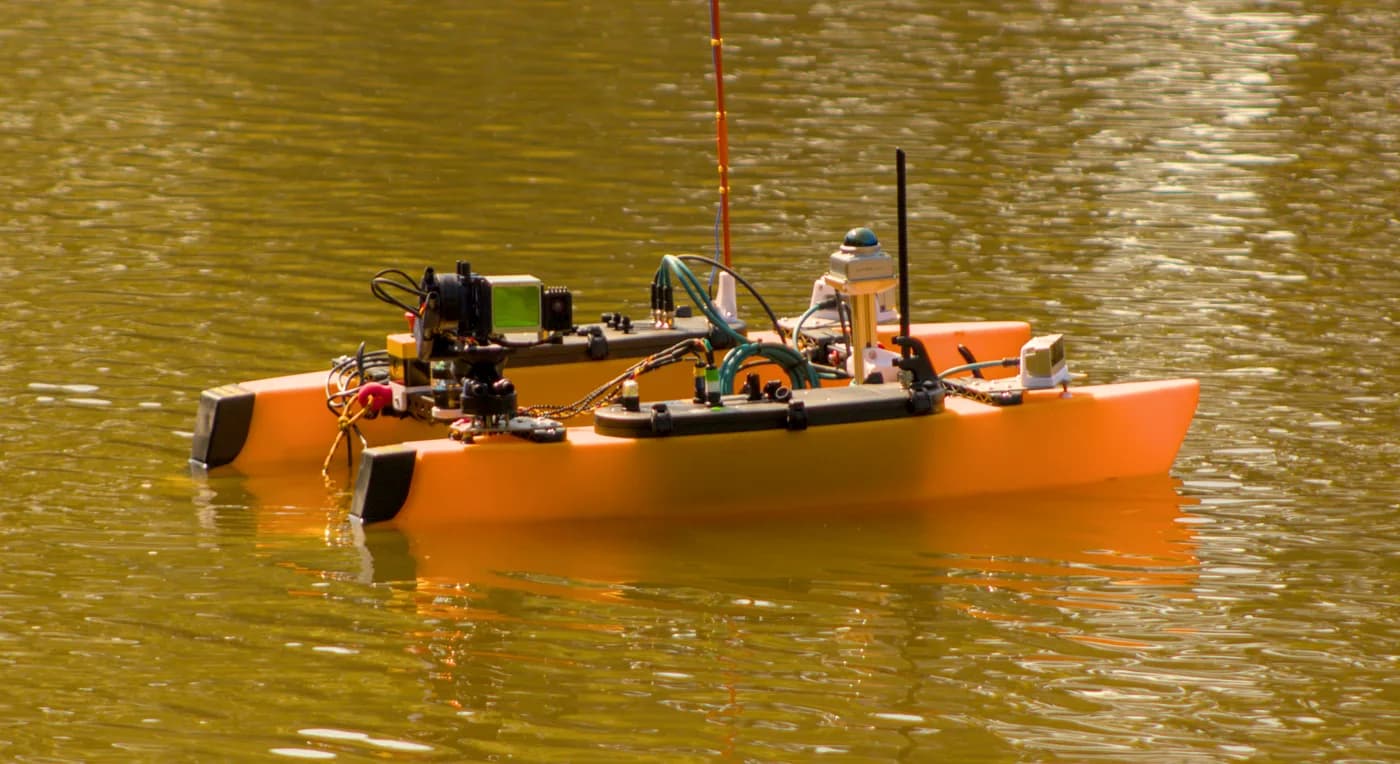
Hydrodynamically optimized BlueBoat catamaran hull fitted with custom structural crossbars, equipment bays, motor brackets, and mounting interfaces for the 2-DOF water shooter and sensor payloads.
Boat mechanical design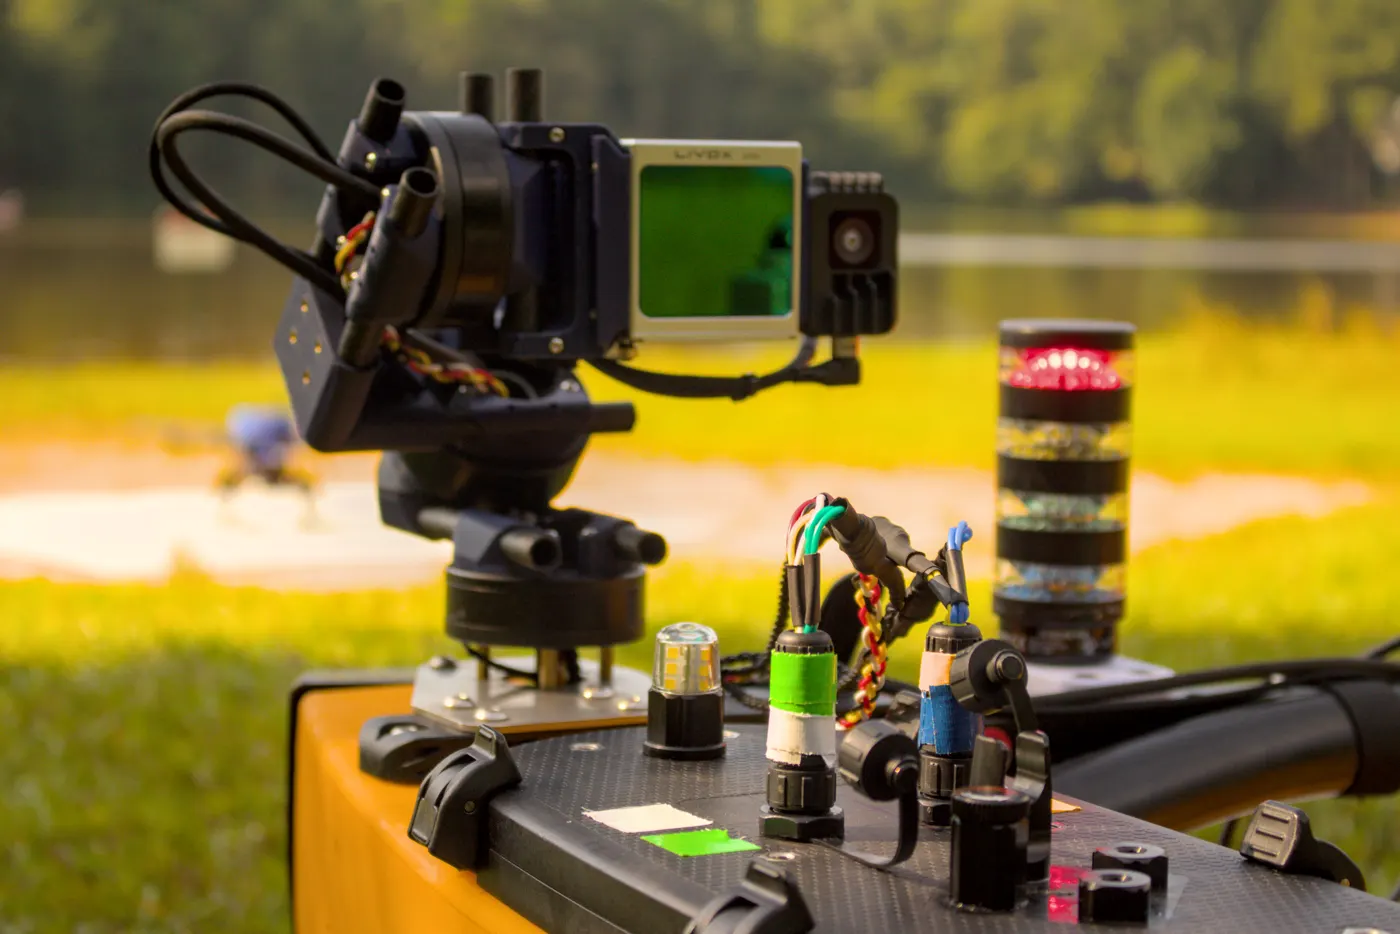
High-capacity Lithium-ion battery system powering isolated compute and propulsion buses, PRESto electromechanical cutoff relays, frontseat Raspberry Pi with Navigator hat, and backseat Nvidia Jetson Orin Nano.
Boat electrical design
Camera and LiDAR detections become persistent object tracks via JIPDA. A BehaviorTree.CPP architecture runs each task, reacts to competition incidents, and resumes execution seamlessly.
Boat softwareModified Holybro X650 carbon-fiber airframe featuring extended landing skids, motor vibration dampeners, and a 3D-printed cruciform payload cradle holding two delivery tins with permanent magnet retention.
Drone mechanical design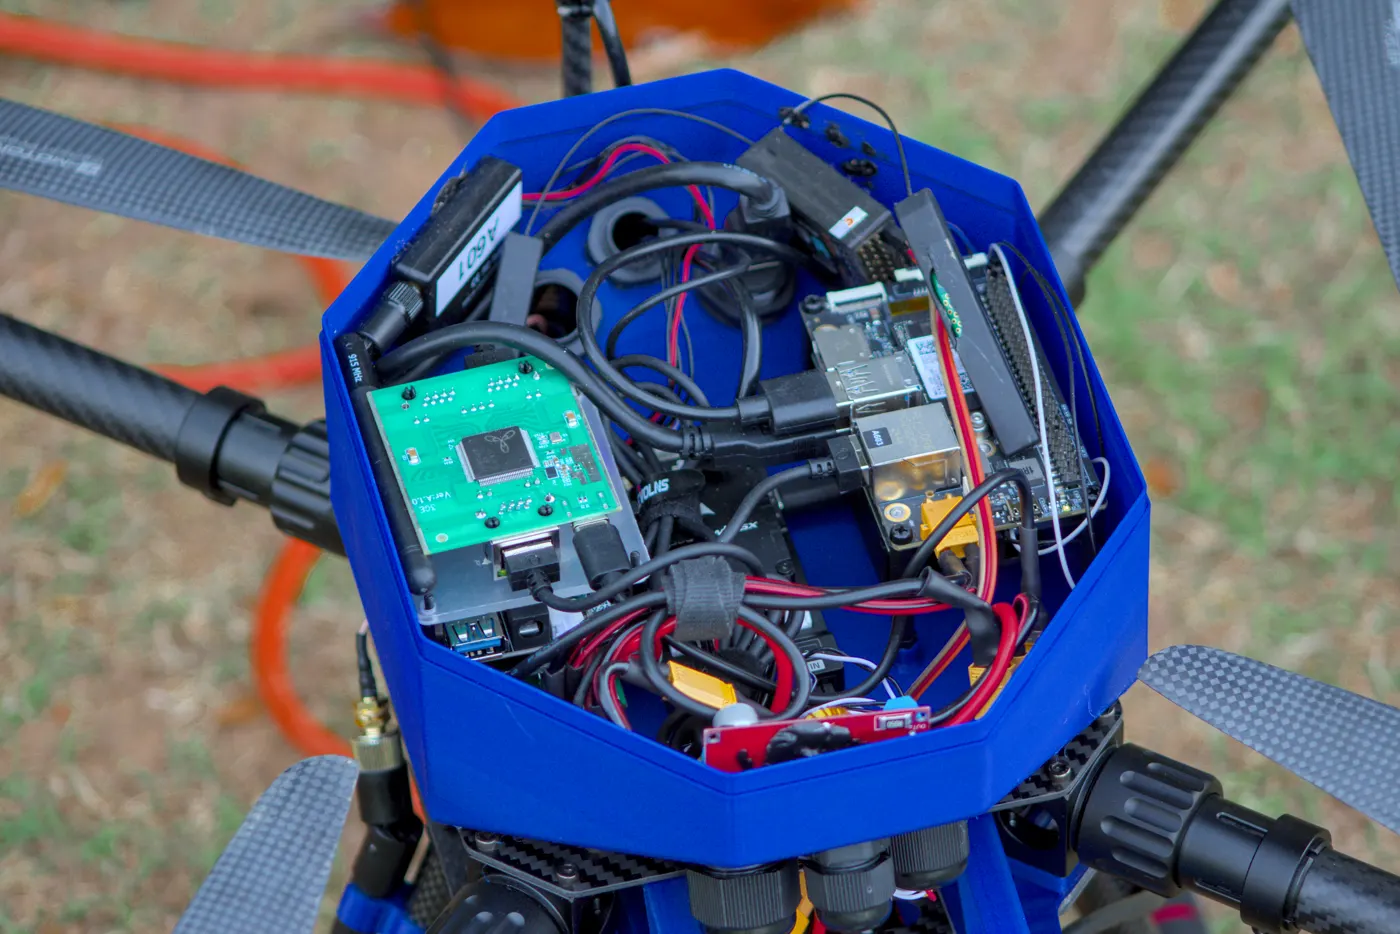
Four 6S 22.2V LiPo battery bank with hot-swap power distribution, powering a Pixhawk flight controller, nadir-mounted Ainstein US-D1 radar altimeter, and an Nvidia Jetson Orin Nano for onboard vision inference.
Drone electrical design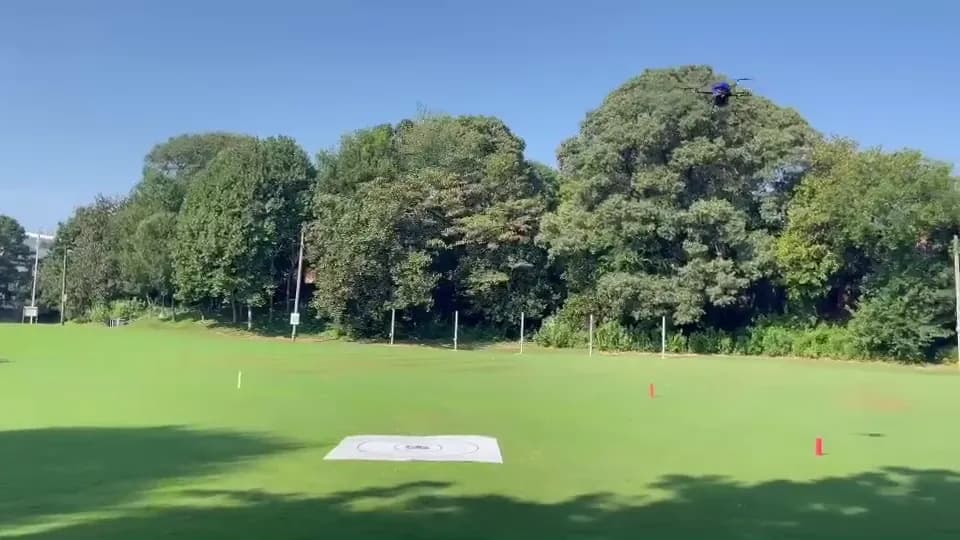
Autonomous flight with geofence, altitude fence, and comms-loss failsafes, sharing what it sees with the boat.
Drone softwareEvery field day, pool test, and simulation run is logged with its objective, time on the water or in the air, and what we changed afterward.
Latest: Aug 27, UAV pool buoyancy check.
See the testing timeline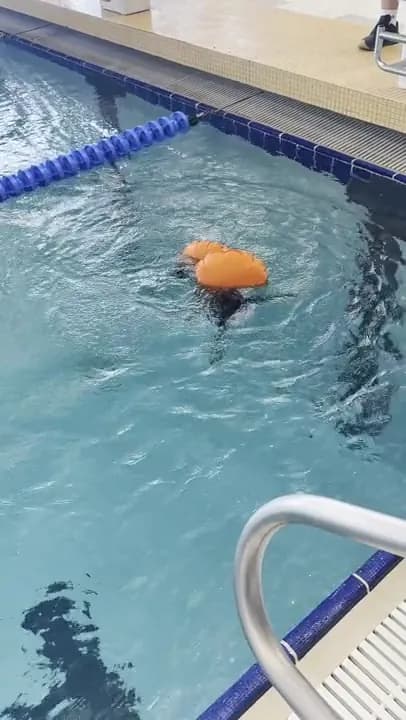 Aug 27, buoyancy
Contact us at marinerobotics@groups.gatech.edu
© 2023-2026 MRG