
Surface Vehicle (USV)
BlueBoat-derived autonomous catamaran featuring frontseat-backseat compute, obstacle-aware navigation, and 2-DOF water shooting.
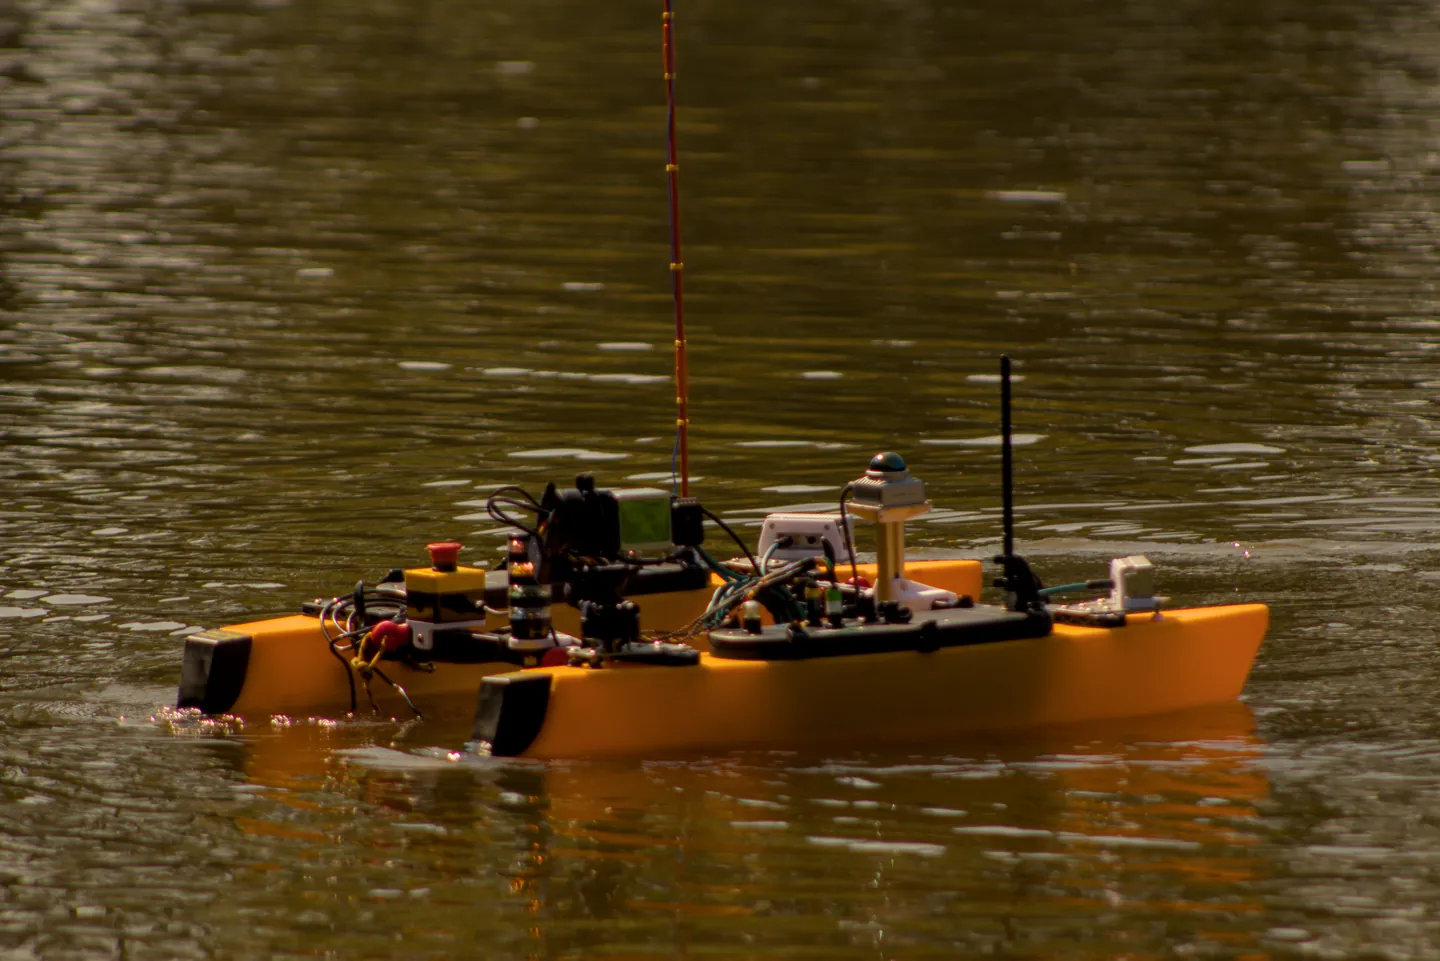
Hull Mechanical Architecture and Structural Mounts
The primary competition vessel is derived from the Blue Robotics BlueBoat catamaran. Leveraging proven hydrodynamic hull lines, buoyancy characteristics, and modular aluminum crossbars, the mechanical integration adds custom CNC-machined structural crossbars, waterproof penetrator plates, motor bracket dampeners, and a payload deck that houses task hardware, including the 2-DOF water shooter and sensor gimbal.
Electrical Power and Compute Architecture
The electrical system is divided into isolated propulsion and compute power buses to protect sensitive avionics from motor back-EMF and current spikes:
- Power Regulation & Cutoff: High-capacity Lithium-ion (Li-ion) batteries feed isolated DC-DC buck regulators providing dedicated 12 V and 5 V rails. Propulsion current passes through the PRESto electromechanical cutoff relay for physical emergency shutoff.
- Frontseat Low-Level Controller (Raspberry Pi + Navigator Hat): Runs ArduRover firmware dedicated to PWM thruster signaling, GPS/IMU sensor reading, manual RF control decoding, and hardware safety monitoring.
- Backseat High-Compute Node (Nvidia Jetson Orin Nano): Executes high-bandwidth ROS 2 workloads, including YOLOv11 neural inference, JIPDA multi-sensor fusion, dual-map occupancy grid generation, and BehaviorTree.CPP autonomy.
Navigation and Obstacle-Avoidant Path Planning
The USV navigation system operates in layers above the ArduRover autopilot. A visibility graph planner using an A* search algorithm computes collision-free transit paths around mapped obstacles and prohibited task boundaries. The vehicle follows waypoints using direct target setpoints or velocity control with line-of-sight carrot-chasing to manage path tracking under wind and surface currents.
Two-DOF Water Shooter Subsystem
For the dock-based target engagement task, the USV mounts a two-degree-of-freedom water shooting system sized to continuously strike a target 2.0 m away at an elevation of 1.5 m. The subsystem consists of:
- Yaw Steering: A waterproof servo mounted to the forward crossbar that steers the nozzle ±90° relative to the vessel centerline, allowing precise targeting while the vessel maintains dock-avoidance positioning.
- Submersible Pump & Hydrodynamic Shroud: A 12 V IP68 water pump mounted low on the hull inside a custom shroud that reduces drag and filters aquatic debris.
- Pressure Control & Laminar Nozzle: A brushed motor controller regulates pump RPM to adjust stream distance, discharging through a 3D-printed nozzle optimized for laminar flow to resist wind dispersion.